محرك العاصمة
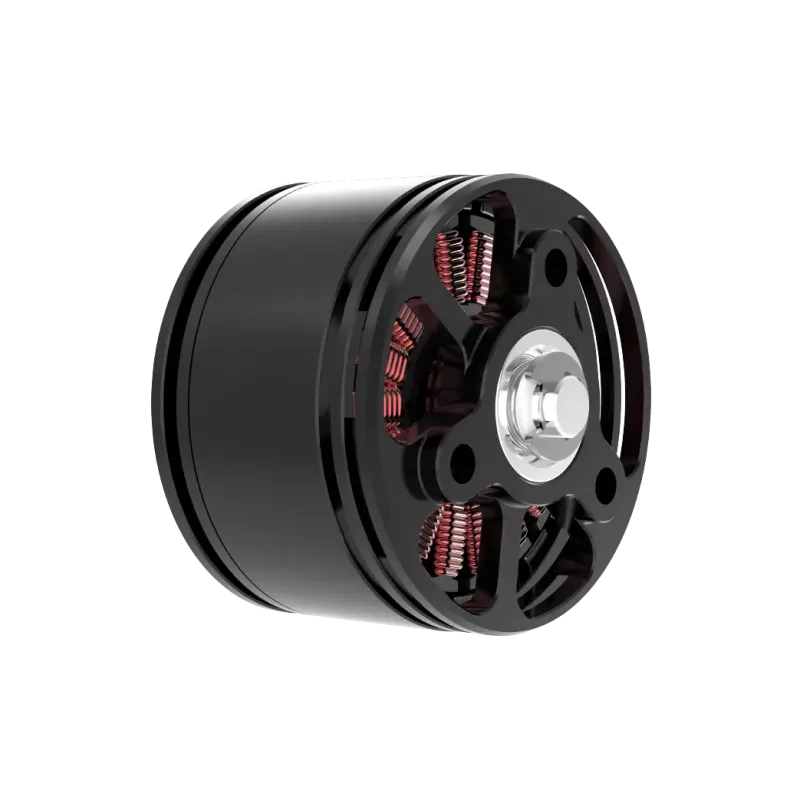
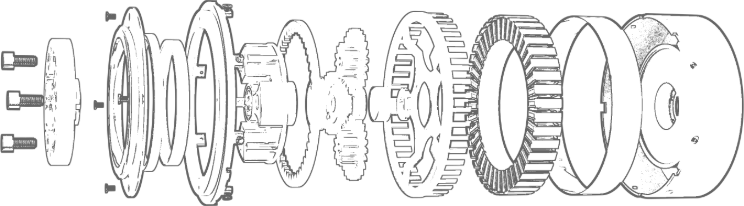
أالعاصمةمحرك is generally divided into two types: محركات العاصمة المصقولةومحركات التيار المستمر بدون فرش. It is one of the most basic types of rotary motors. When DC power is applied, a magnetic field is generated through electromagnetic effects, causing the internal rotor to spin at high speed.
Taking the محرك DC مصقول as an example, the control principle is quite simple: you can change the supply voltage or use PWM (Pulse Width Modulation) to adjust the average voltage. A higher PWM duty cycle generally means a higher motor speed. Reversing the polarity of the power supply changes the direction of rotation. (Note: Brushless DC motors require an electronic speed controller for electronic commutation).
DC motors have a simple structure, low cost, high speed, and relatively simple drive circuits. Simply apply power and the motor starts spinning. However, without an angle sensor, there is no way to know how many revolutions it has completed or which angle it has stopped at. A gearbox is often added to increase the output torque. This combination is commonly known as a geared DC motor.

محرك السائر
أمحرك السائر contains multiple stator coils. The external driver energizes these coils in a specific sequence, causing the rotor to rotate step by step through a fixed angle, known as the step angle.
The number of input pulses sent by the driver determines the rotation angle. For example, sending 200 pulses can make the motor complete one full revolution.
The pulse frequency determines the motor's rotation speed. The faster the pulses are sent, the faster the motor rotates.
Stepper motors offer high positioning accuracy in open-loop control and do not require feedback from an angle sensor. As long as the motor is not overloaded and does not lose steps, the rotation angle is determined by the number of pulses sent. However, torque decreases as speed increases. If the load is too high or the speed changes too quickly, the motor may lose steps. Once this happens, the control system cannot detect the position error on its own.

ان
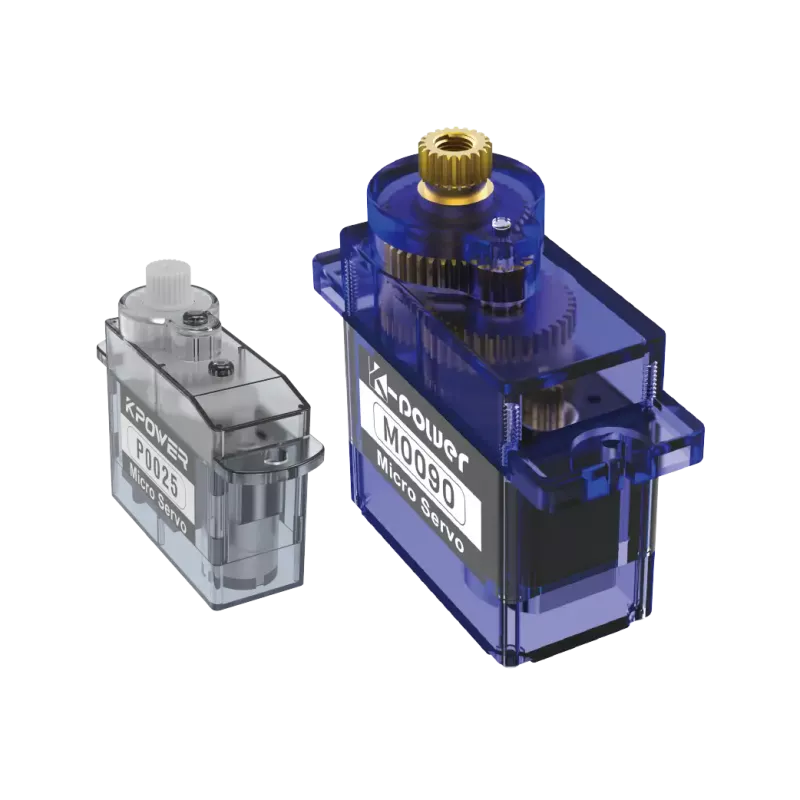
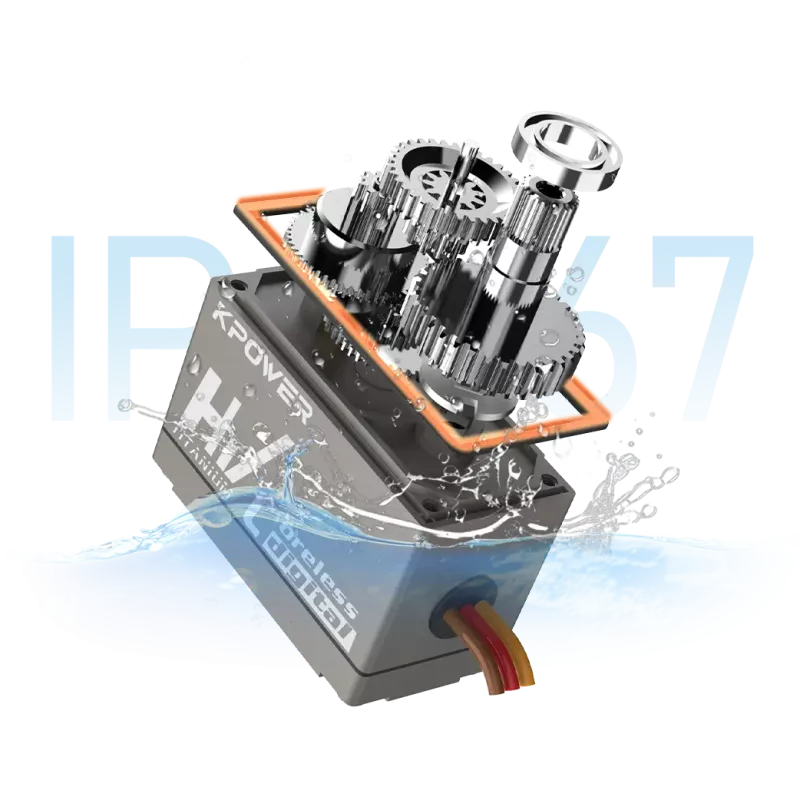
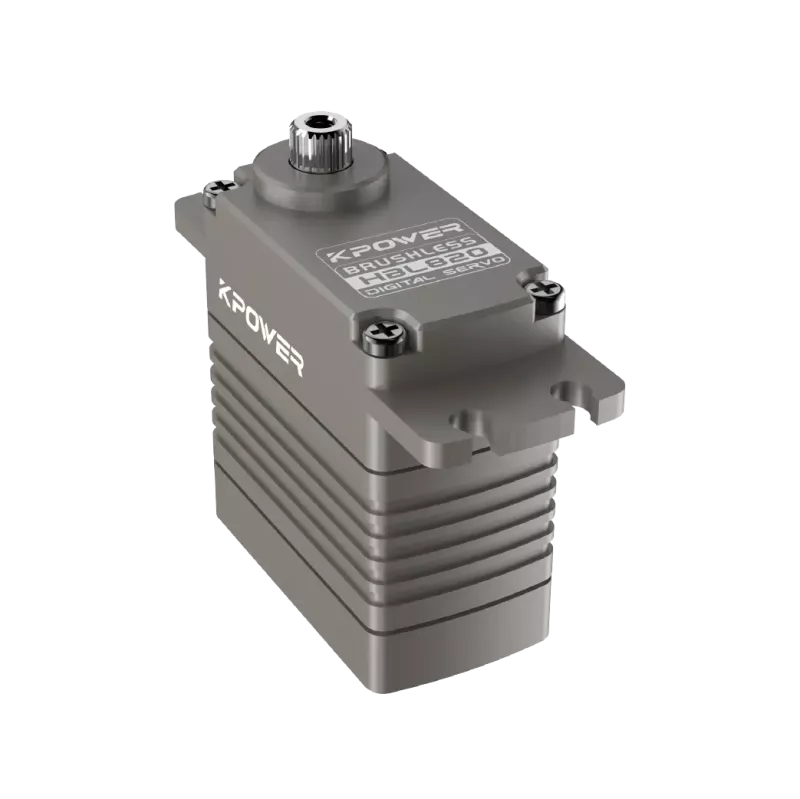
RCمضاعفات is a highly integrated, closed-loop miniature
مضاعفات system. It typically contains a small DC motor, a reduction gearbox, a potentiometer (angle sensor), and a control circuit board.
Inside the servo, the angle sensor and control circuit continuously compare the target angle with the actual angle detected by the sensor. The control circuit automatically adjusts the motor's rotation direction until the servo reaches the desired position and holds it there.
The control signal for an RC servo is usually a fixed-period PWM signal.
The duration of the high-level signal (pulse width) directly determines the target angle. For example:
A pulse width of 0.5 ms corresponds to 0°.
A pulse width of 1.5 ms corresponds to 90°.
A pulse width of 2.5 ms corresponds to 180°.

Comparison & Selection Guide
ميزة | محرك DC ناعم | محرك السائر | أجهزة RC |
وضع التحكم | Open-loop (Speed) | Open-loop (Position/Speed) | Closed-loop (Position) |
Position Accuracy | None (without encoder) | High (within step angle) | معتدلة إلى عالية |
Speed Range | عالية جدًا | Low to Medium | قليل |
عقد عزم الدوران | لا | Yes (at standstill) | نعم |
Typical Use Cases | RC toy cars, cooling fans | 3D printers, CNC routers | Robotic arm joints, RC plane rudders |